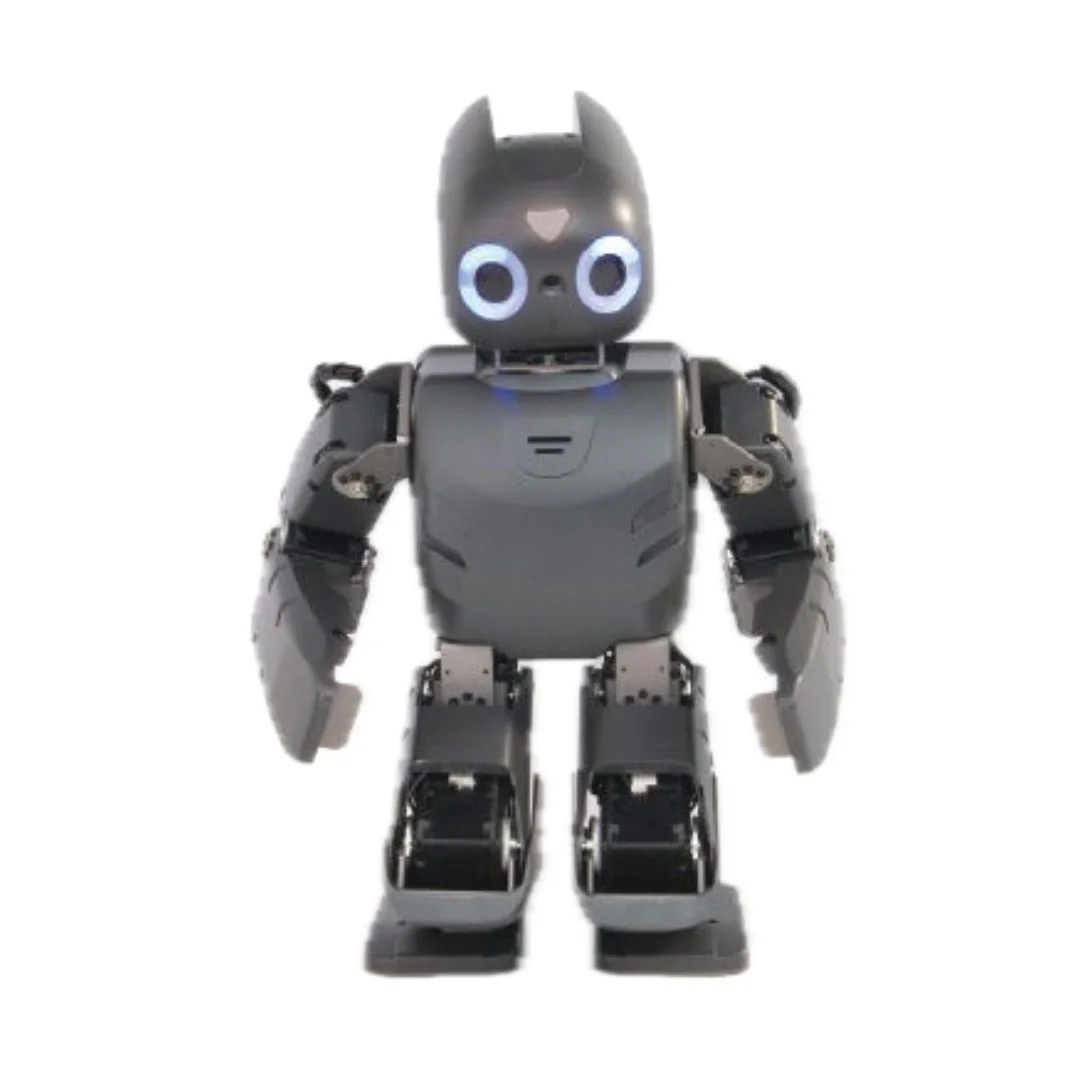
Photo credits: Robotis
Humanoid robot flexible movement open source platform DARWIN-OP Robotis
Find more information about the product below.
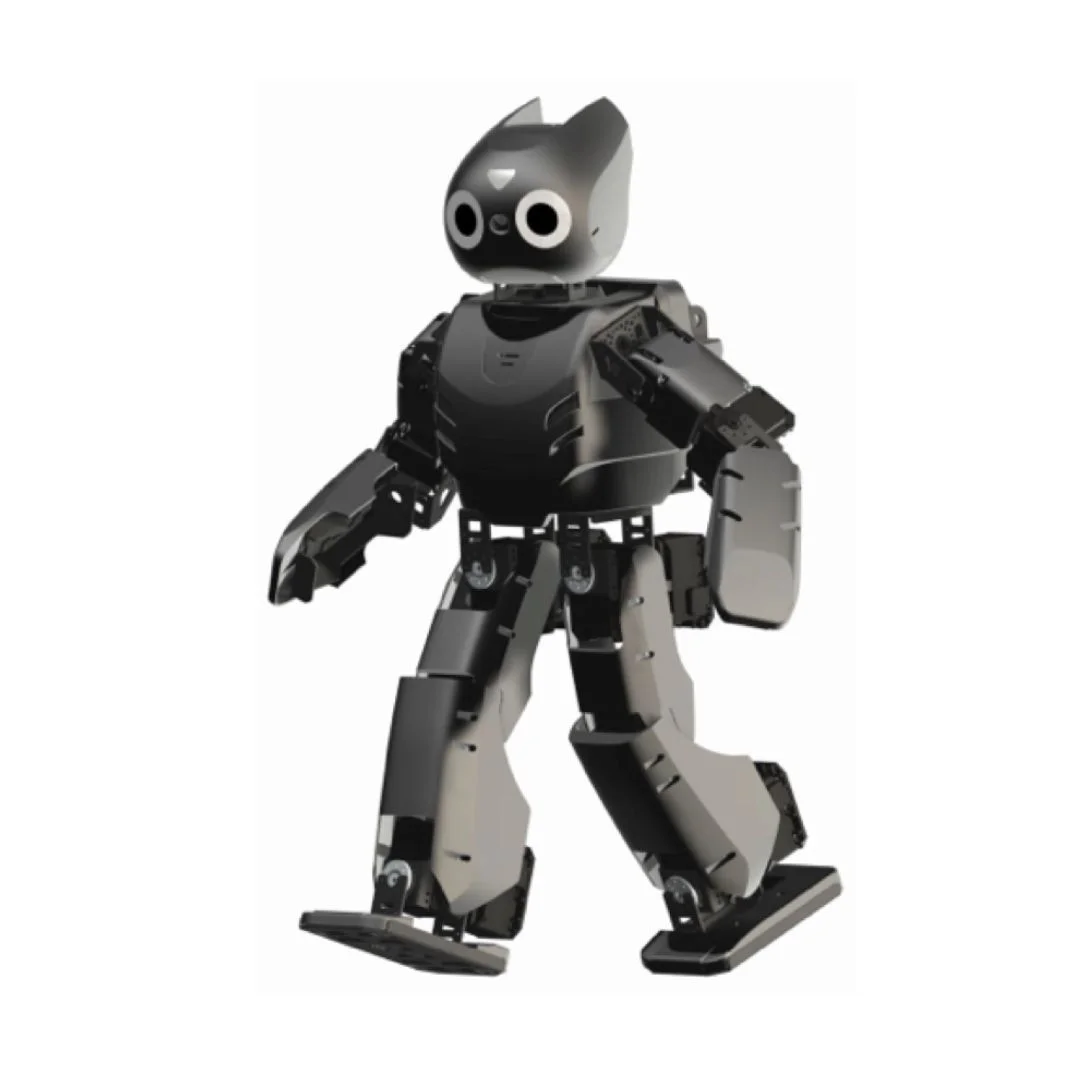
DARwIn-OP is an affordable miniature humanoid robot with advanced computing power, sophisticated sensors, high payload capacity and dynamic motion capability to enable many exciting research and education activities.
What is DARWIN-OP?
DARwIn-OP (Dynamic Anthropomorphic Robot with Intelligence-Open Platform) is an affordable miniature humanoid robot platform with advanced computing power, sophisticated sensors, high payload capacity, and dynamic motion capability to enable many exciting research and education activities.
Open source and completely open platform
The designation “open source” applies to software whose license meets criteria precisely established by the Open Source Initiative, that is to say the possibility of free redistribution, access to the source code and to derivative works.

The DARwIn-OP platform is completely open thanks to:
- its PC computer base running the Linux-Ubuntu operating system;
- available hardware specifications (electronic card, 3D model);
- available software specifications (source codes and software component kit);
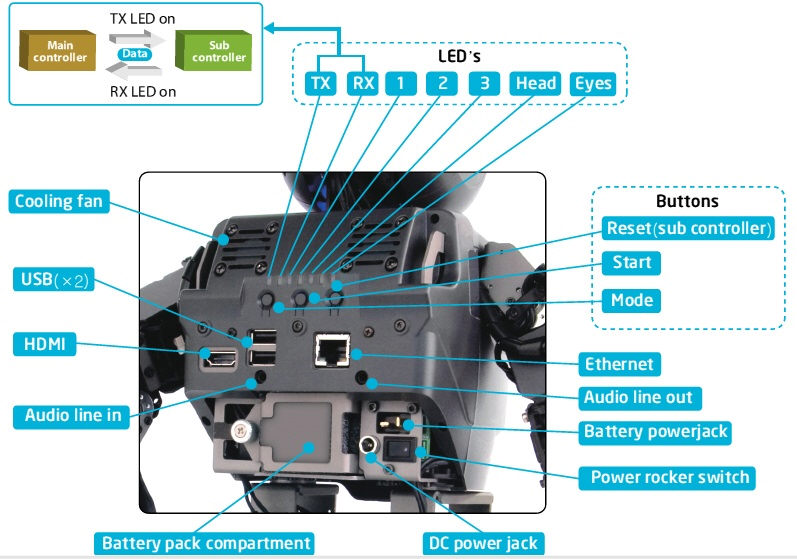
- possible extensions with 13 inputs/outputs and an analog/digital port;
- a modular structure for easy maintenance.
High performance and advanced features
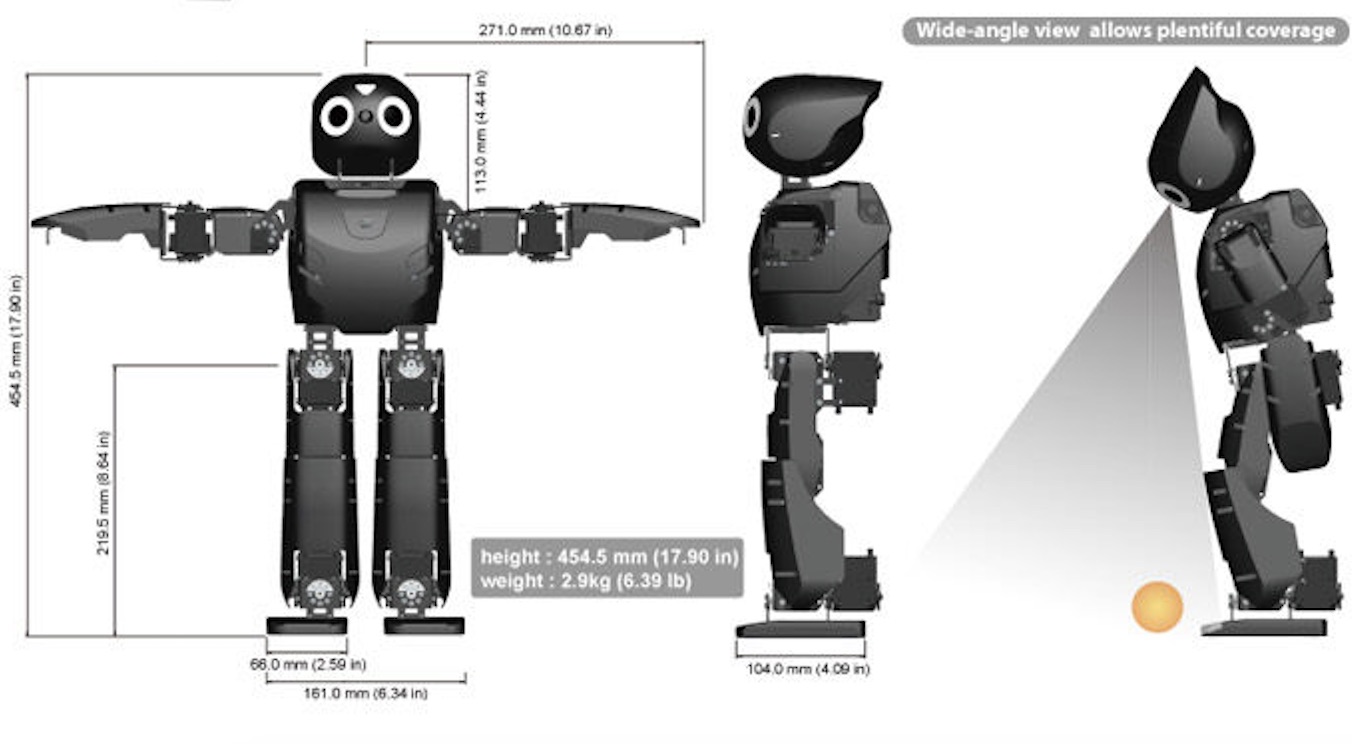
- Default walking speed: 24,0 cm/s (9,44 in/s) 0,25 sec/step - user-changeable gait
- •Integrated PC: 1,6 GHz Intel Atom Z530 embedded 4 GB flash SSD
- • Management controller (CM-730): ARM CortexM3 STM32F103RE 72 MHz
- • 20 actuator modules (6 DOF legs x2 + 3 DOF arms x2 + 2 DOF necks)
- • Actuators with durable metal gears (DYNAMIXEL MX-28)
- • Self-maintenance kit (easy to follow steps and instructions)
- • Sleep mode for low power consumption
- • High-speed 3 Mbps Dynamixel bus for joint control
- • Battery (30 minutes of operation), charger and external power adapter
- (The battery can be removed from the robot without turning off by connecting the external power supply before removing it)
- • Versatile functionality (can accommodate legacy, current and future devices)
- • 3-axis gyroscope, 3-axis accelerometer, x3 button, x2 detection microphone
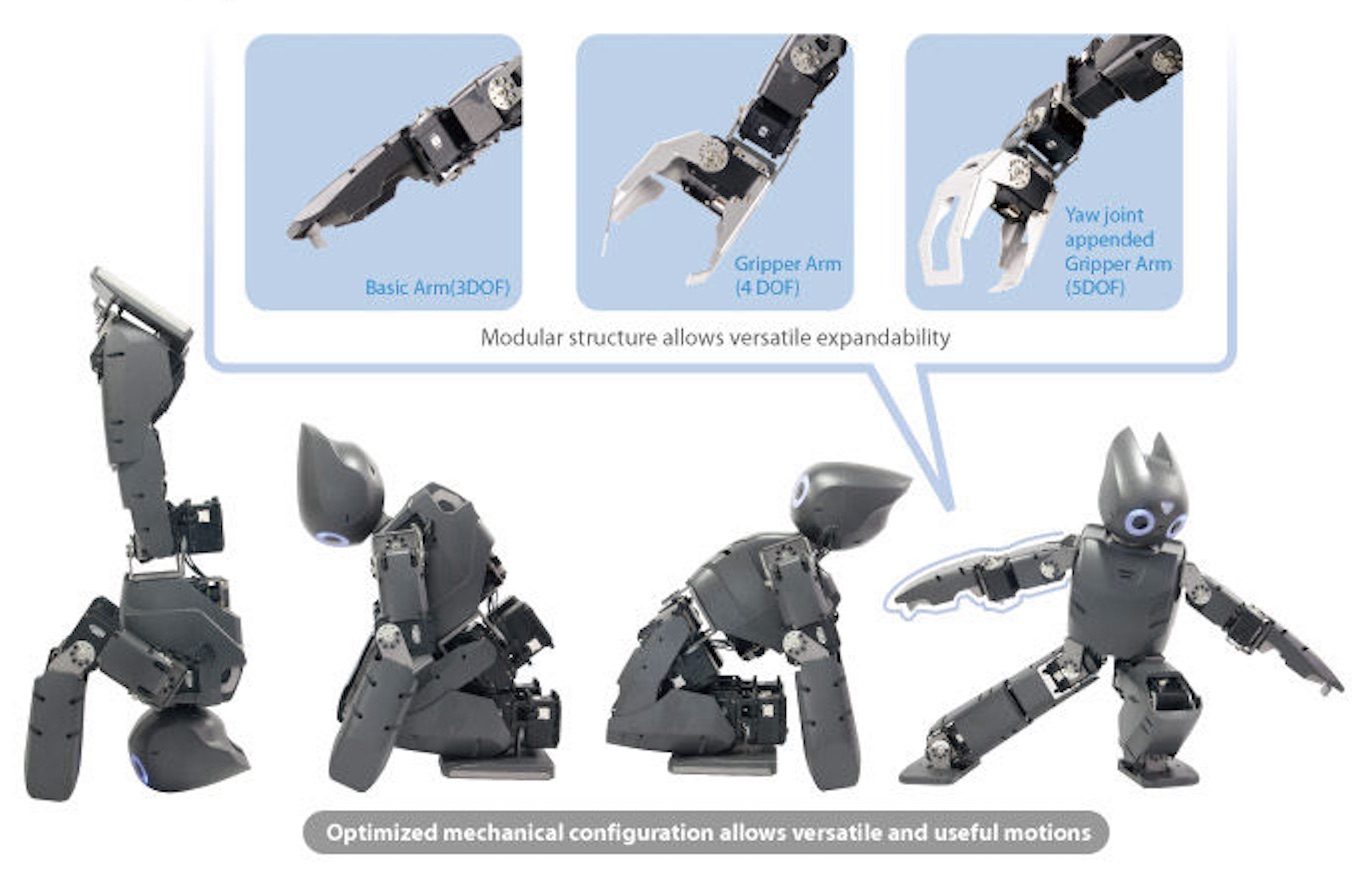
Efficient and versatile modular configuration
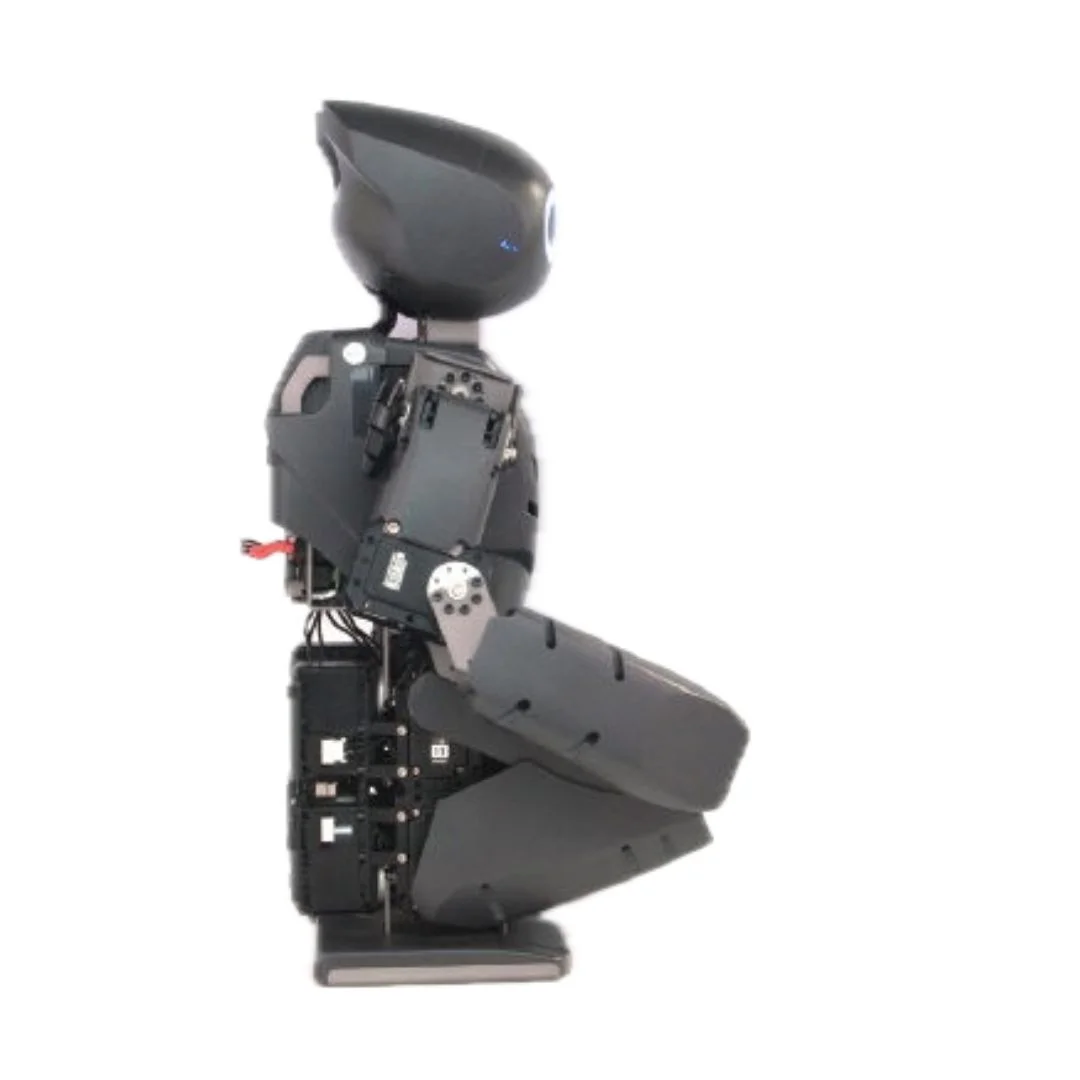
The modular structure allows for versatile expansion. The optimized mechanical configuration allows for versatile and useful movement.
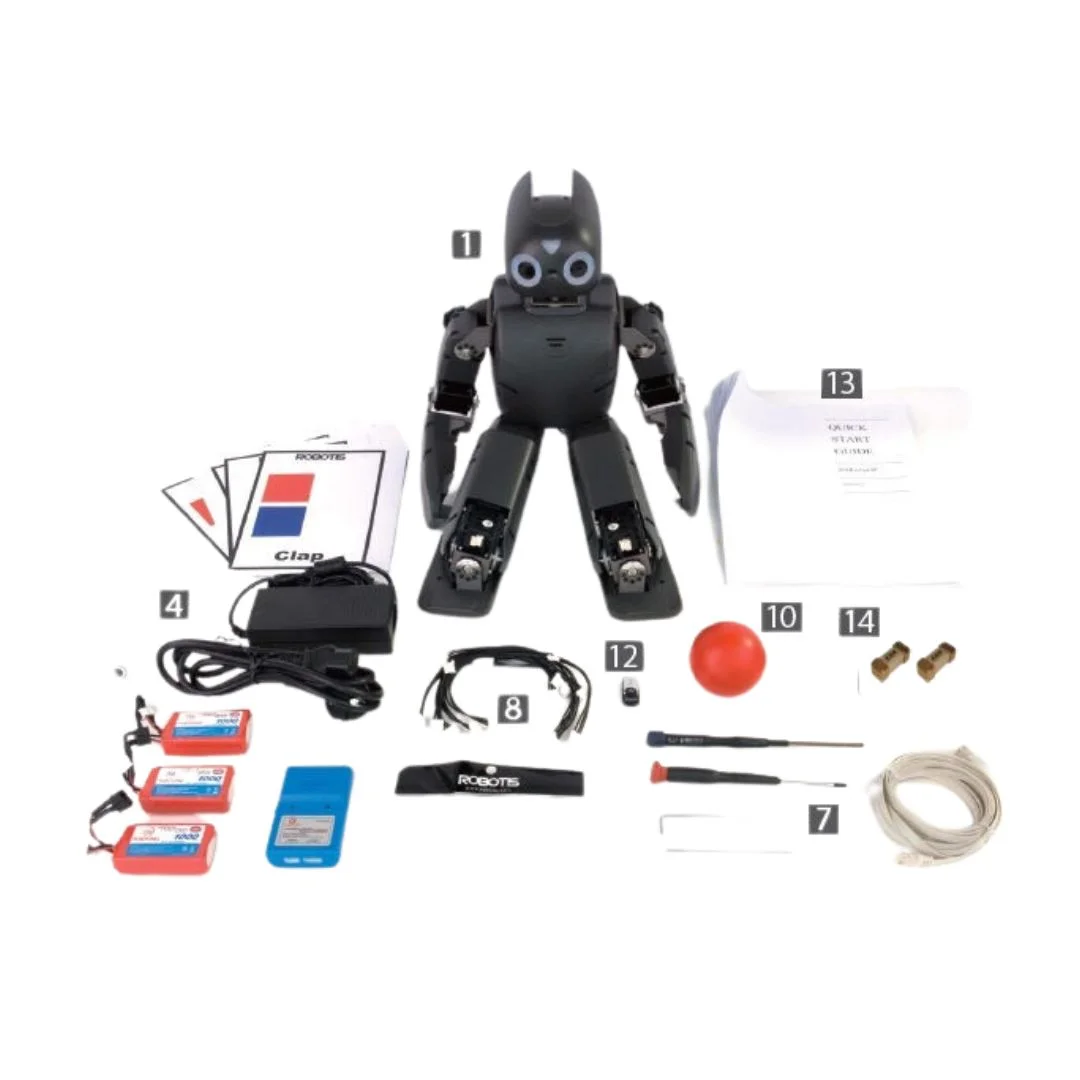
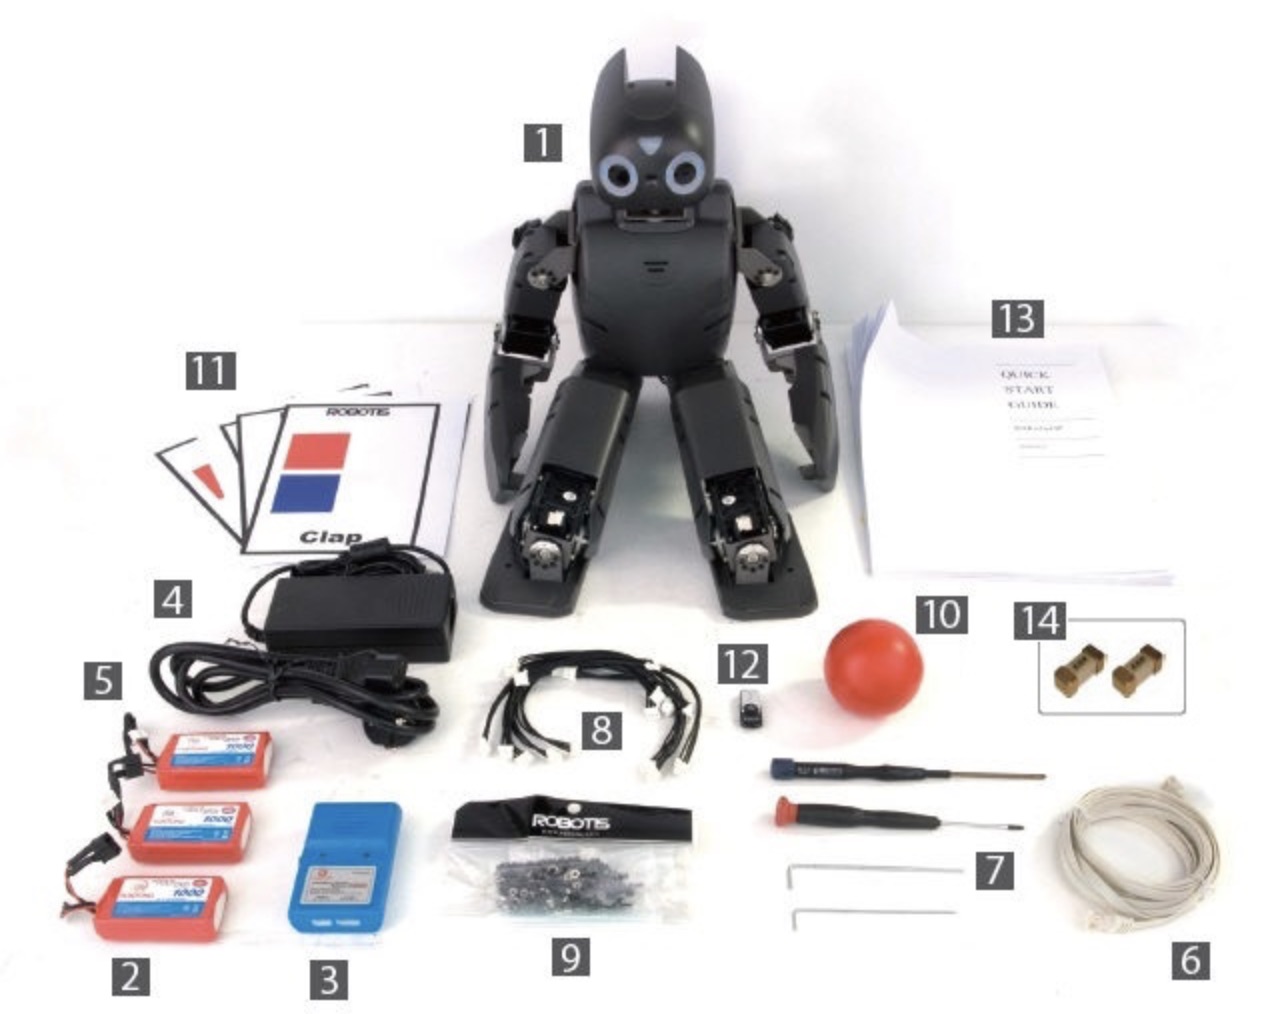
Package contents
- Fully assembled DARWIN-OP robot
- 3 packs of batteries
- 1 battery charger
- 1 DC Power Supply
- 1 power cable
- 1 Ethernet cable
- 2 keys, 2 screwdrivers
- 1 set of spare cables
- 1 set of spare bolts and nuts
- 1 red ball
- 1 set of color patches (7 individual)
- 1 USB stick (with recovery software installed)
- 1 quick start guide
- 2 spare fuses
Dimensions and size