Photo credits: Hiwonder
EDU+ programmable robot with JetOver LIDAR, Slamtec A1 3D camera, ROS1 ROS2 AI image and sound recognition, robotic arm, holonomic wheels, Ackermann or tracks
Find more information about the product below.
JetRover is a composite ROS robot developed for ROS education scenarios.
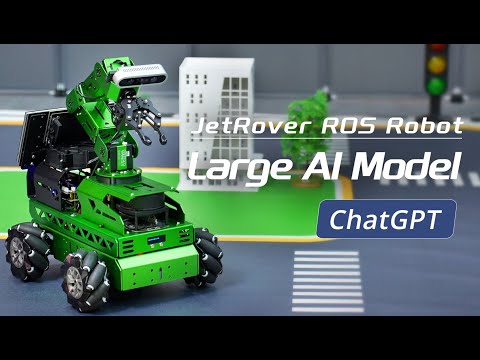
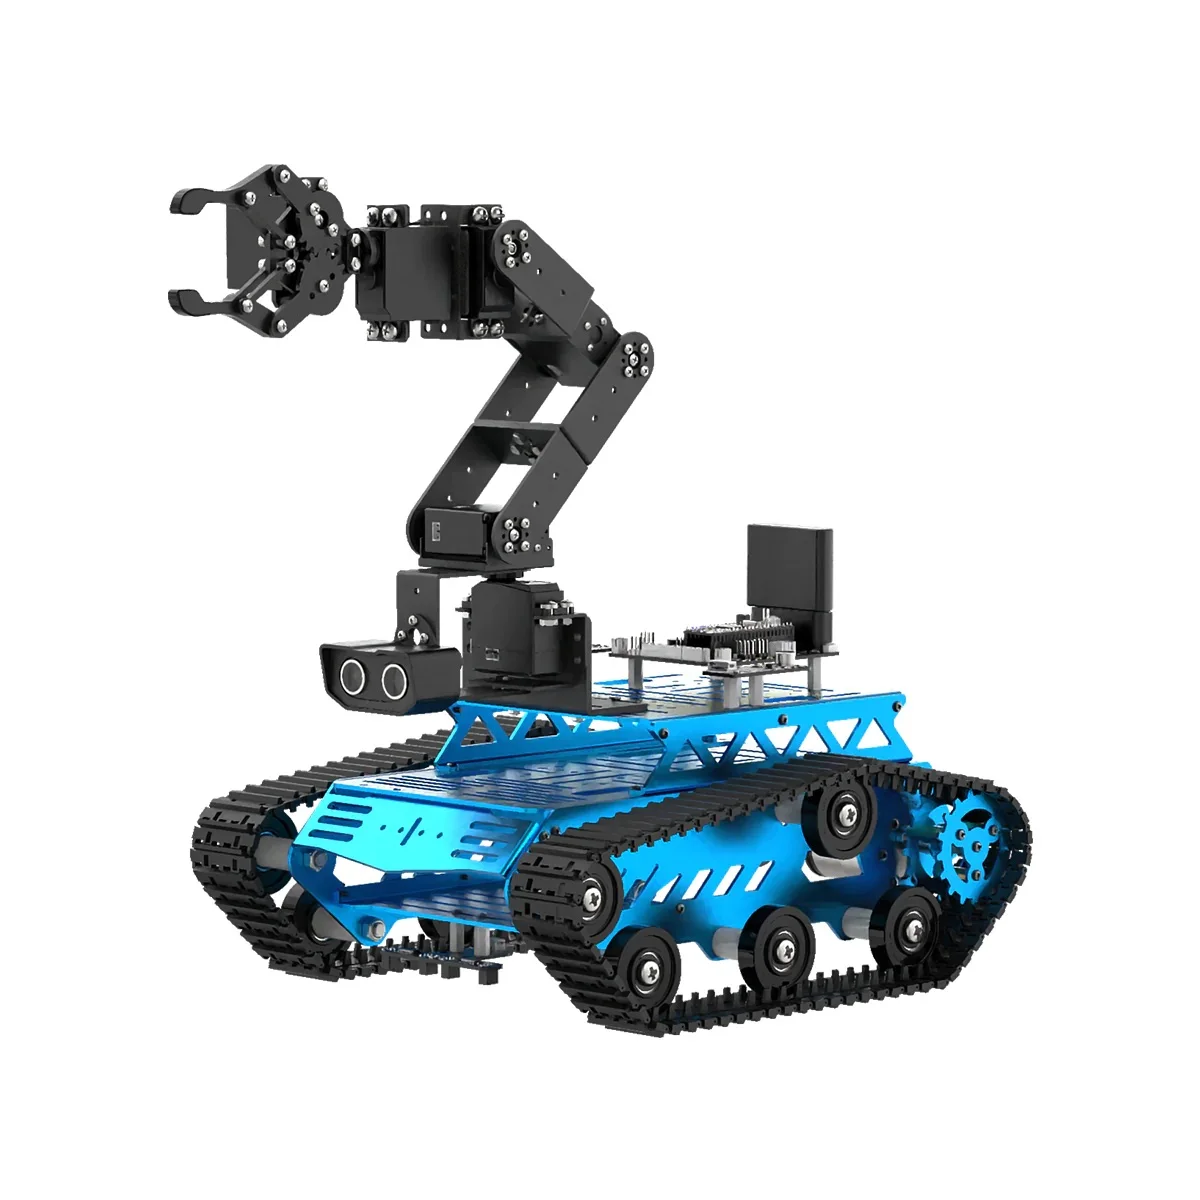
It supports 3-movement chassis: Mecanum wheel, Ackerman and Tank chassis.
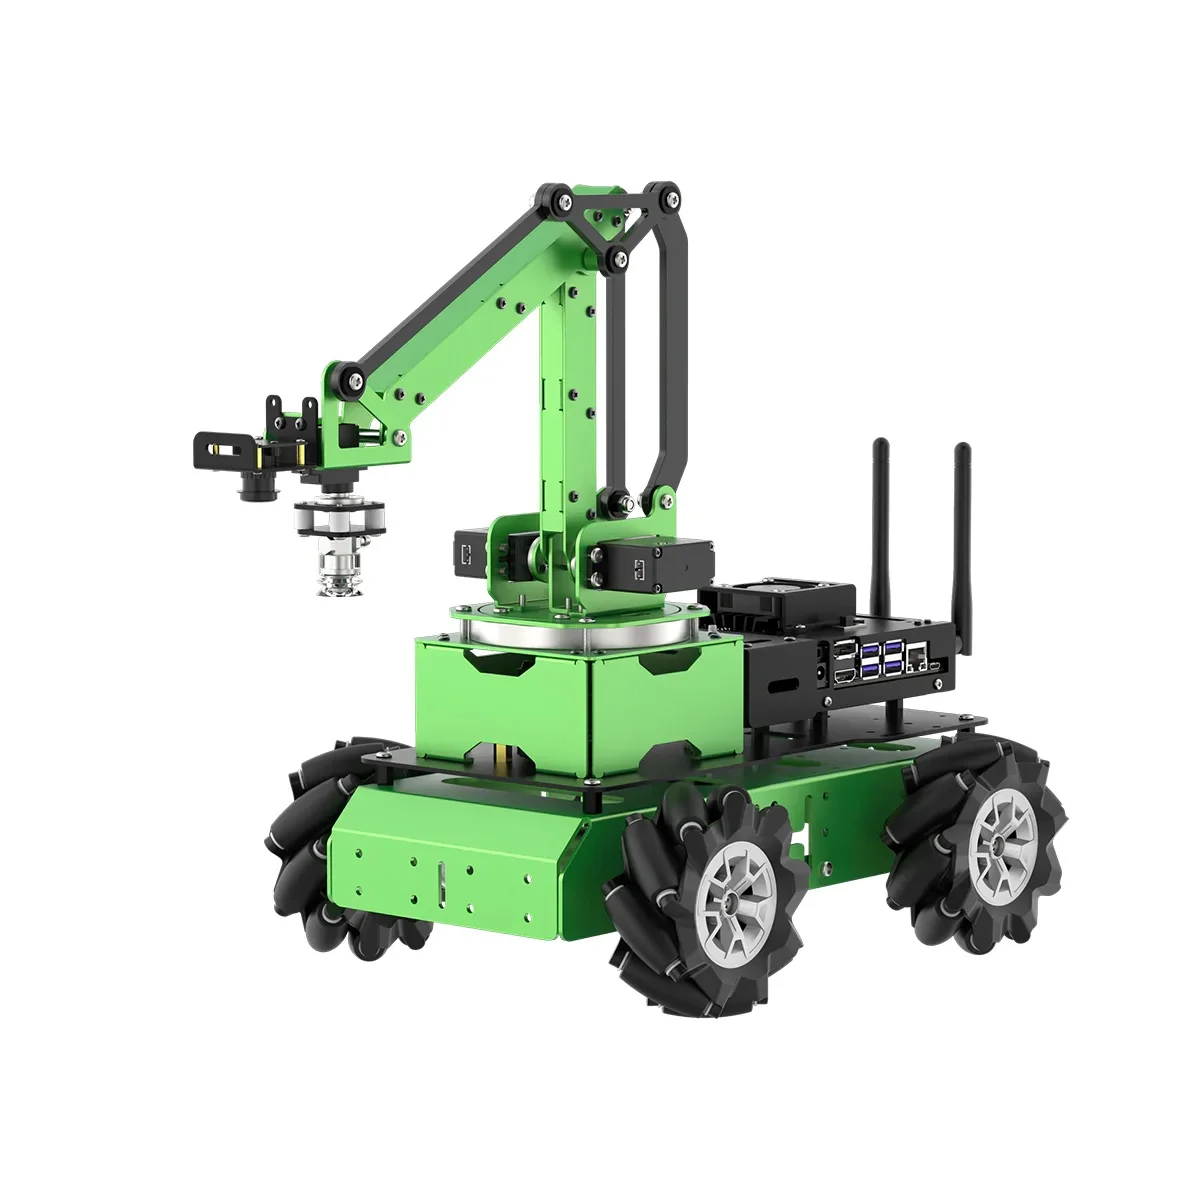
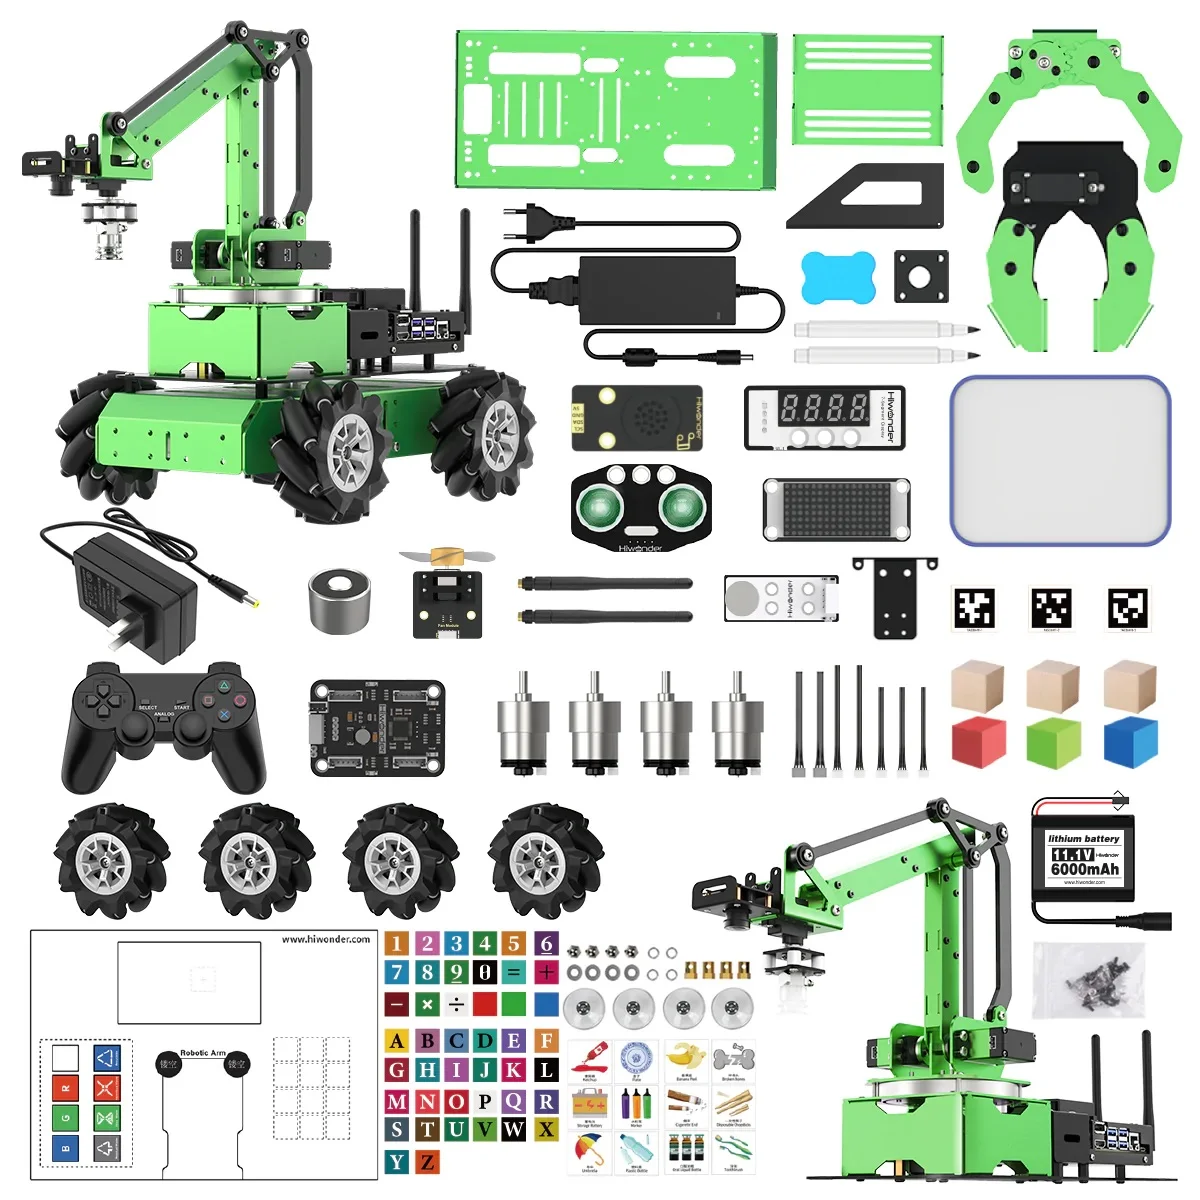
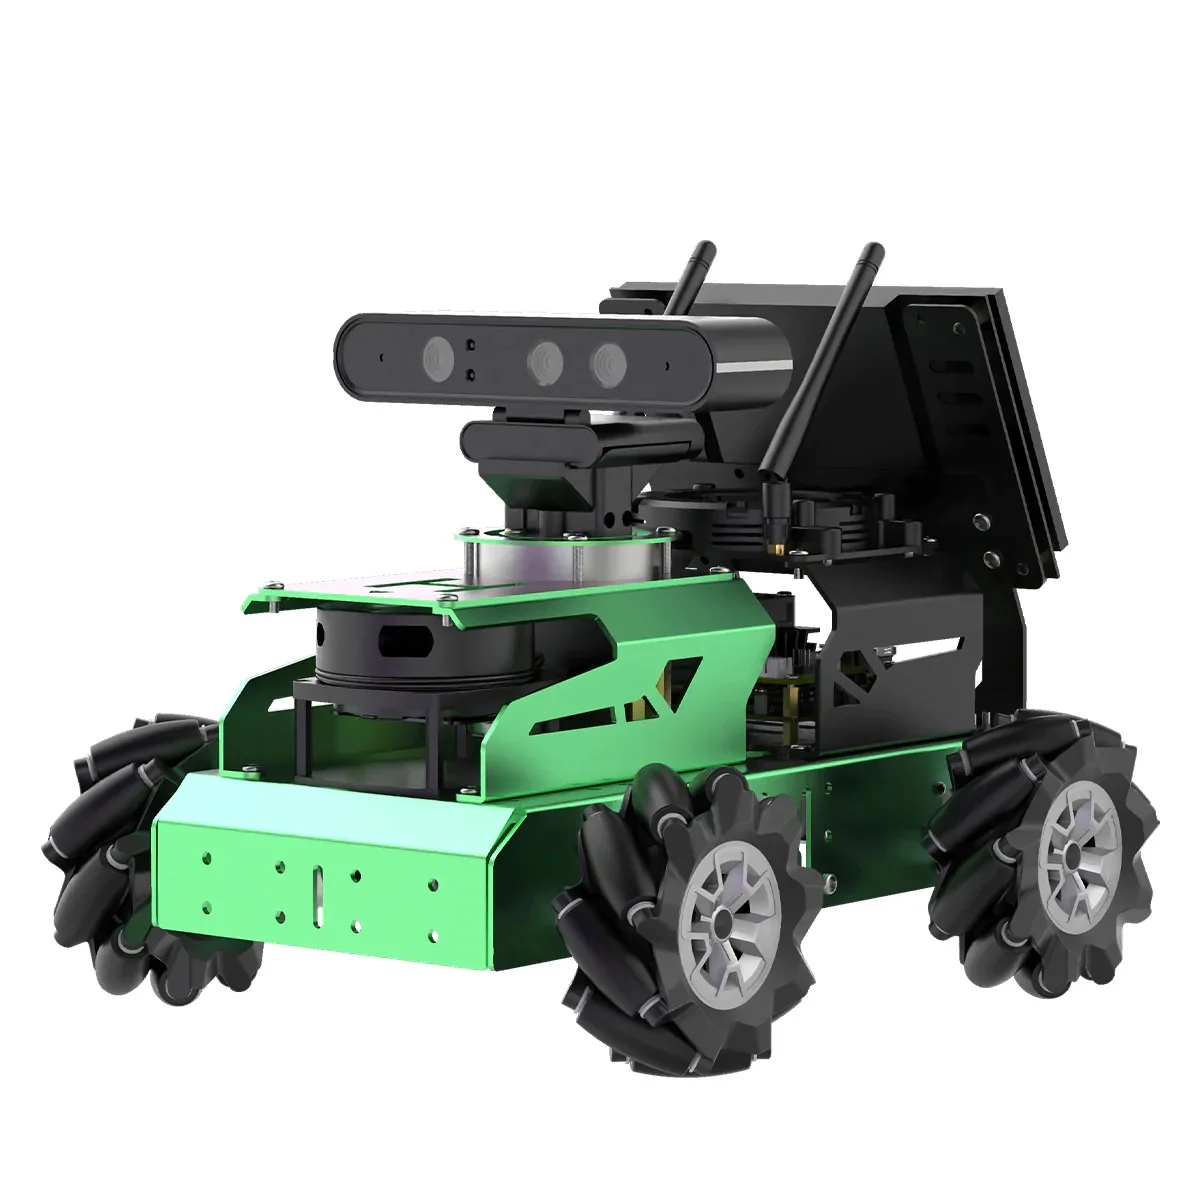
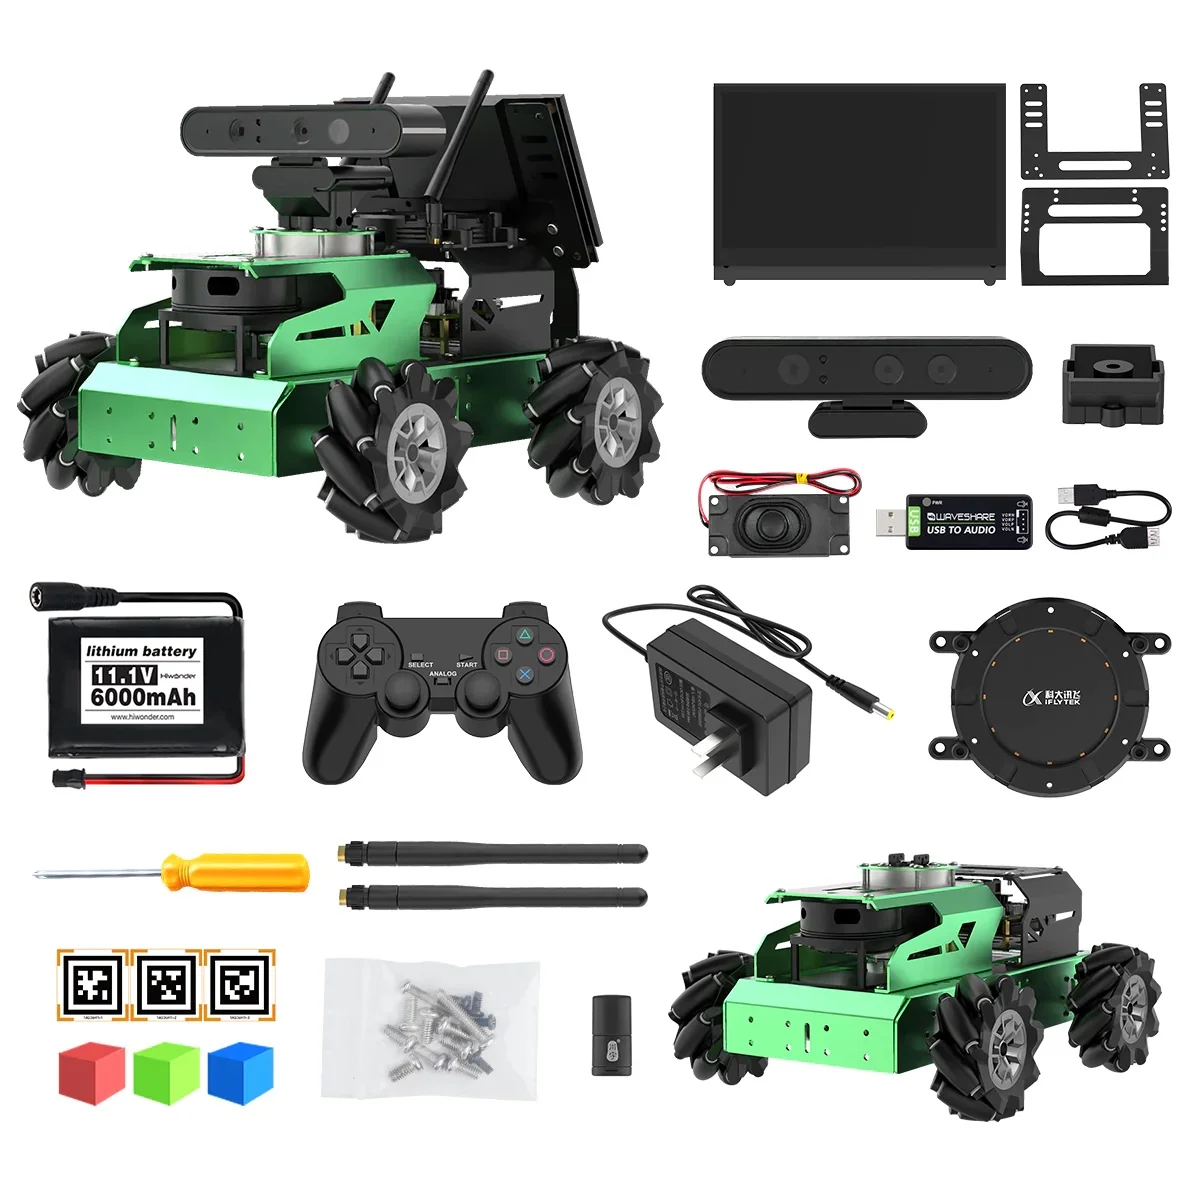
JetRover is equipped with an NVIDIA Jetson or Raspberry Pi, a high-performance magnetic encoding engine, and a 6-degree-of-freedom robotic arm. High-performance hardware configurations such as lidar, a 3D depth camera, a 7-inch LCD screen, and a far-field microphone array enable robot motion control, mapping navigation, path planning, obstacle tracking and avoidance, autonomous driving, 3D mapping, navigation and manipulation, somatosensory interaction, far-field voice interaction, group control training, and other applications. The JetRover car robot also deploys multimodal generative AI to support more advanced embedded AI applications. To help you unlock its full potential, we offer open-source code and learning resources to inspire and support your AI projects.

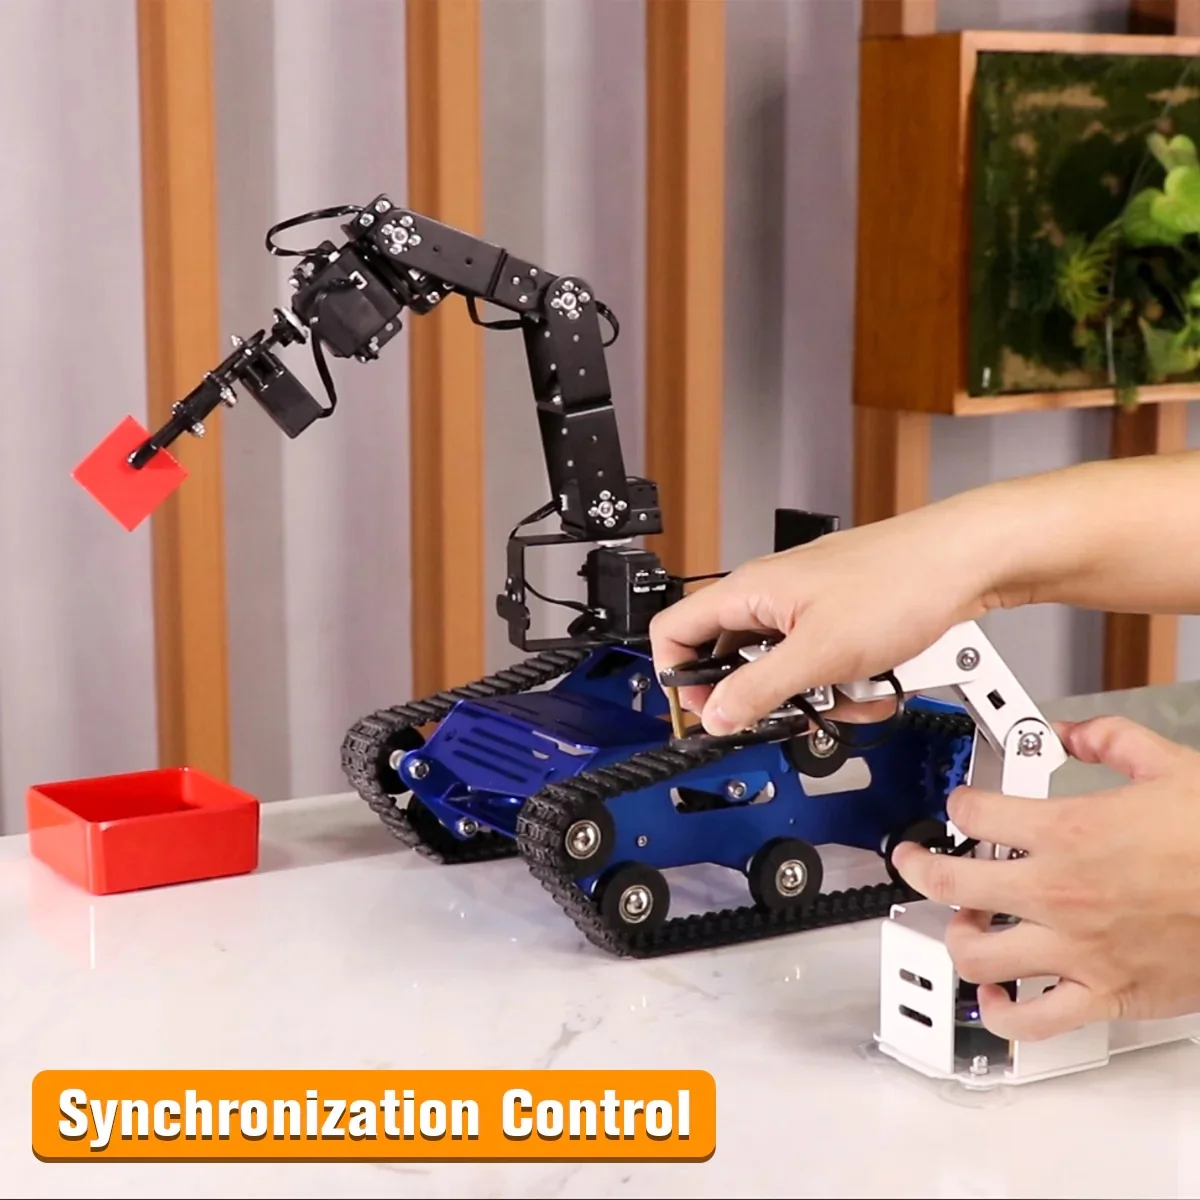
6DOF robot arm, intelligent bus servo
The JetRover robot is equipped with a 6DOF robot arm and a high-torque bus high-voltage servo, which greatly extends the robot's endurance.

SLAM LiDAR mapping navigation
Hiwonder JetRover is equipped with lidar, which can perform SLAM mapping and navigation. It also supports path planning, fixed-point navigation, and dynamic obstacle abundance.

FPV (first-person view) depth vision
JetRover is equipped with a 6-degree-of-freedom robotic arm, fitted with a high-performance 3D depth camera at the end, which can perform target recognition, tracking, and capture.

6CH Field Microphone Array
The 6CH far-field microphone array and speakers support sound source positioning, voice recognition control, voice navigation, and other functions.

Integration of the large AI model with SLAM mapping and navigation
The Hiwonder JetRover combines a large multimodal AI model to understand user voice commands via a large AI language model, enabling multipoint navigation. Once the JetRover arrives at the designated location, it uses a vision language model to gain a deep understanding of surrounding objects and events. This approach significantly enhances the robot's intelligence, adaptability, and overall user experience, making it better suited to meet real-world needs.
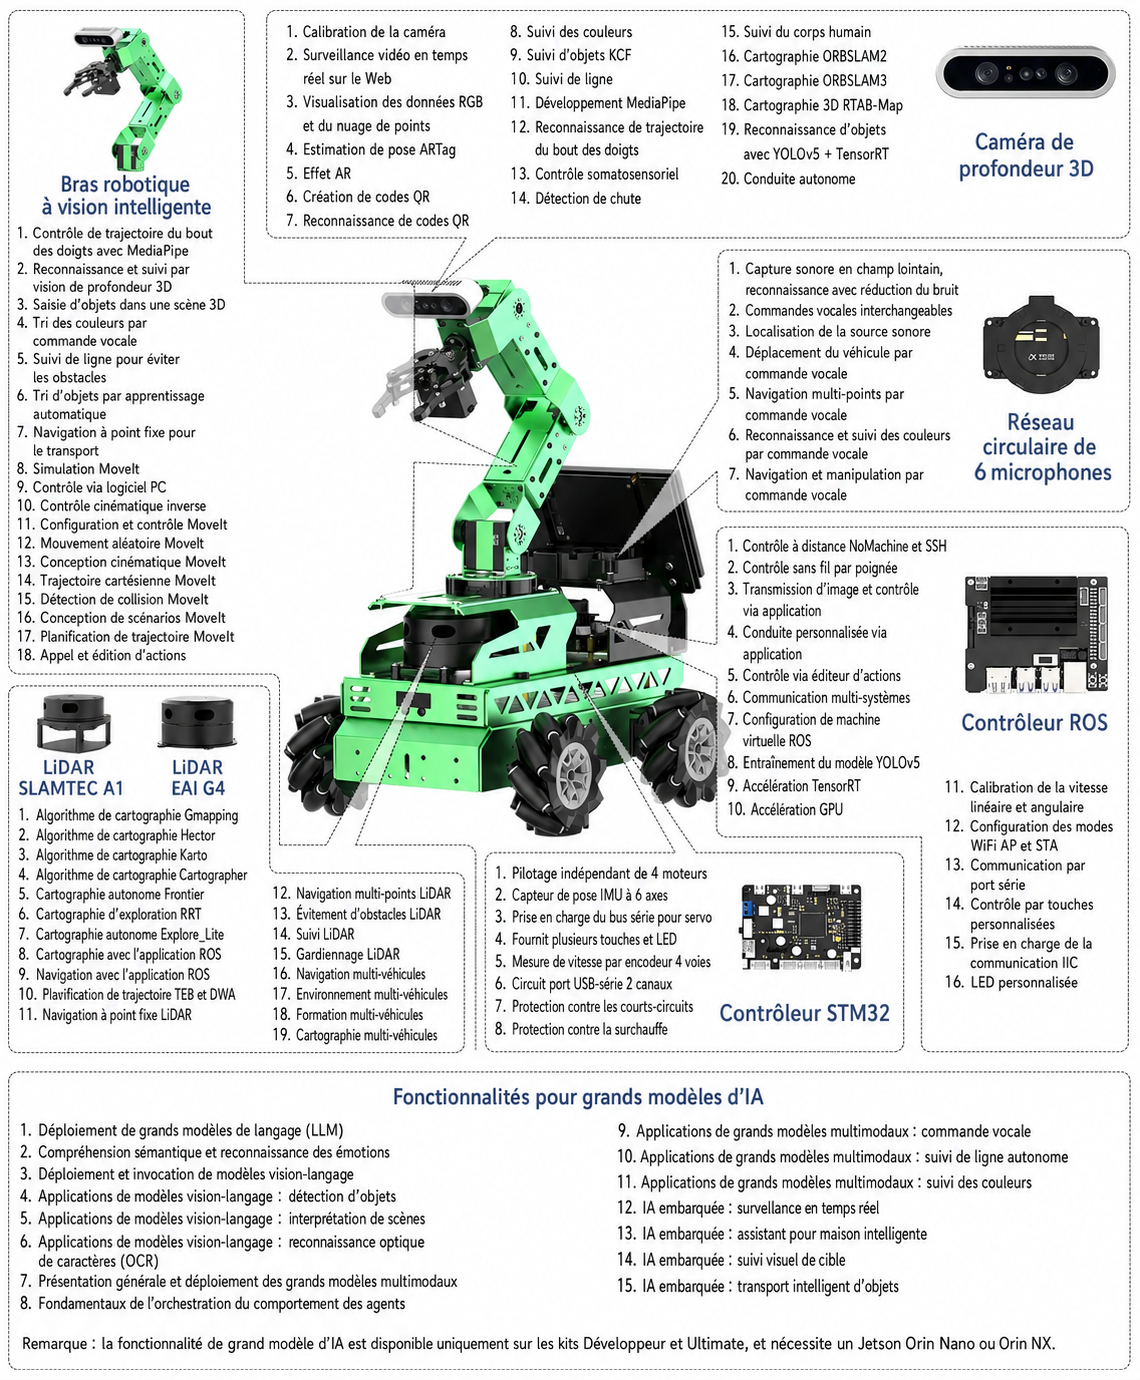
Semantic comprehension

Environmental perception

Intelligent navigation

Scene comprehension

Embedded generative AI applications

AI Vision Interaction
KCF target tracking

Next line of sight

Color recognition and tracking
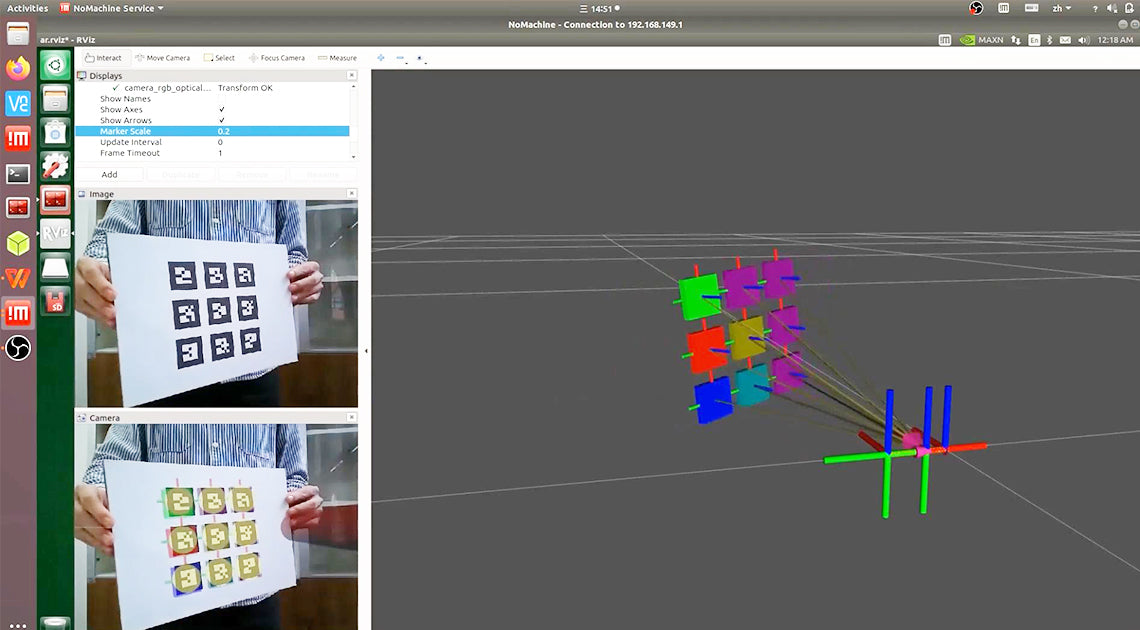
Augmented Reality (AR)

MediaPipe development, enhanced AI interaction

AI Deep Learning Framework