Photo credits: Hiwonder
Construction and programming robot research kit JetHexa ROS Jetson Nano hexapod with depth camera Lidar mapping and SLAM navigation
Find more information about the product below.
JetHexa is an open-source hexapod robot based on the Robot Operating System (ROS). It is armed with NVIDIA Jetson Nano, intelligent serial bus servos, Lidar camera and monocular/3D depth camera to implement robot motion control, mapping and navigation, obstacle tracking and avoidance, personalized roaming, human feature recognition, somatosensory interaction.
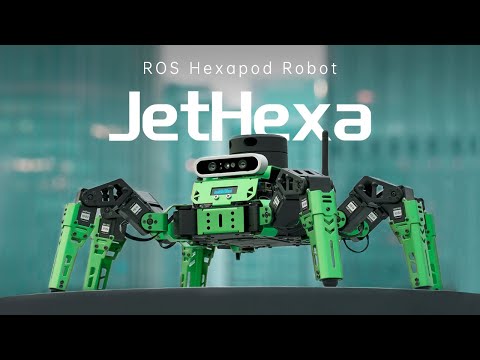
Featuring new inverse kinematics algorithm, tripod and undulation gaits, highly configurable body posture, height and speed, JetHexa will bring the ultimate user experience to the user.
JetHexa not only serves as an advanced platform for user to learn and verify hexapod movement, but also provides solutions for ROS development. To help user embark on a new journey in ROS hexapod robotic world, many ROS and robot learning materials and tutorials are provided.
Nano Jetson Control System
NVIDIA Jetson Nano is capable of running mainstream deep learning frameworks, such as TensorFlow, PyTorch, Caffe/Caffe2, Keras, MXNet, and provides powerful computing power for massive AI projects. Powered by Jetson Nano, JetHexa can realize image recognition, object detection and positioning, pose estimation, semantic segmentation, intelligent analysis and other powerful functions.

2D lidar mapping, navigation and obstacle avoidance
JetHexa is loaded with a high-performance EAI G4 Lidar that supports mapping with various algorithms including Cartographer, Hector, Karto and Gmapping, path planning, fixed-point navigation as well as obstacle avoidance in navigation.

RTAB-VSLAM 3D Vision Mapping and Navigation
Supporting 3D color mapping in two ways, pure RTAB vision and fusion of vision and Lidar, JetHexa is able to navigate and avoid obstacles in the 3D map and perform global relocalization.

Multi-point navigation and obstacle avoidance
Lidar can sense the environment in real time and enable JetHexa to avoid obstacles during multi-point navigation.

Depth map data, point cloud
Using the corresponding API, JetHexa can obtain a depth map, color image and point cloud from the camera.

"Moonwalk" at fixed speed and height
Thanks to the inverse kinematics algorithm, JetHexa can remain stable during SLAM mapping and moonwalking at a constant speed.

Adjusting the pitch angle and rolling angle
Highly configurable body posture, center of gravity, height angle and roll angle enable the hexapod robot to overcome all kinds of complicated terrains.

Direction, speed, pitch and stride adjustment
JetHexa can turn and change lanes while moving, and supports step-free adjustment of linear speed, angular speed, position, height and stride.

Self-balance of the body
The built-in IMU sensor is responsible for detecting body posture in real time to ensure that the robot adjusts its joints to balance the body.
Based on MediaPipe framework, JetHexa can perform human body tracking, hand detection, posture detection, global detection, face detection, 3D detection and more.

ROS Robot Operating System
And it also provides the tools and library functions needed to obtain, compile, write, and run code on all computers. It aims to provide support for code reuse for robotics research and development.